Why a Vacuum’s “Ears” Missed the Corner
An ultrasonic sensor measures distance by sending out a pulse of sound and listening for its echo. The time between the pulse and its return helps the robot estimate how far away an object is. But the echo depends on the object sending sound back toward the sensor.
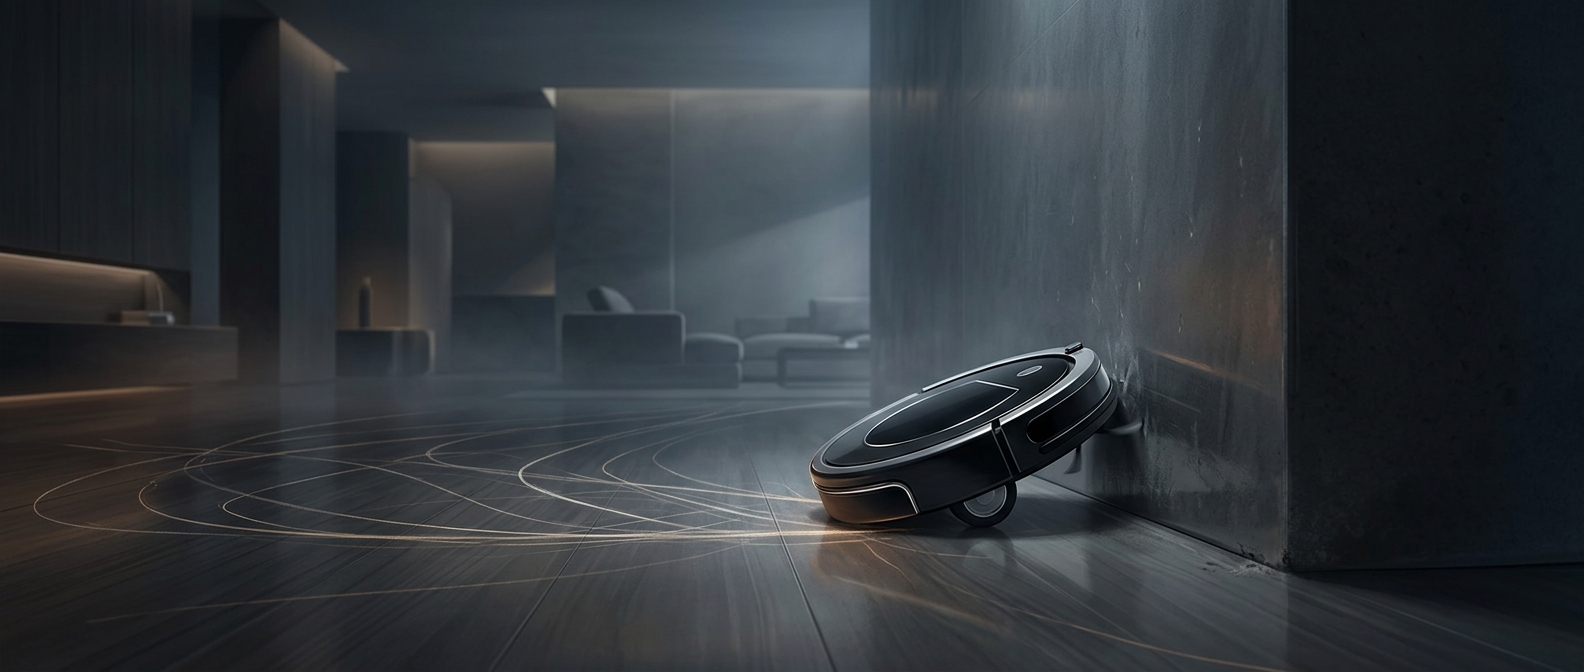
A flat surface facing the sensor is likely to return a strong echo. At a sharp corner, the sound can scatter or bounce away instead. The robot may therefore fail to register the furniture as a nearby obstacle until its bumper makes contact. The sensor is not seeing the corner and choosing to hit it; it is getting an incomplete signal about where the corner is.
A Small Blind Spot Becomes a Long Detour
That missed measurement can disrupt more than one turn. A robot vacuum has to use sensor readings to decide when to slow down, steer, or change direction. If it keeps approaching an obstacle before detecting it, it may repeatedly bump, back away, and try again rather than smoothly route around it.
Carpet can make the result especially noticeable: the machine may spend its remaining charge moving through repeated attempts instead of covering open floor efficiently. Once the battery is depleted, it stops where it is—even if that means stranded on the carpet. The episode shows how a modest weakness in sensing can turn a simple household chore into a navigation loop.