A Wheel That Balances Fore and Aft
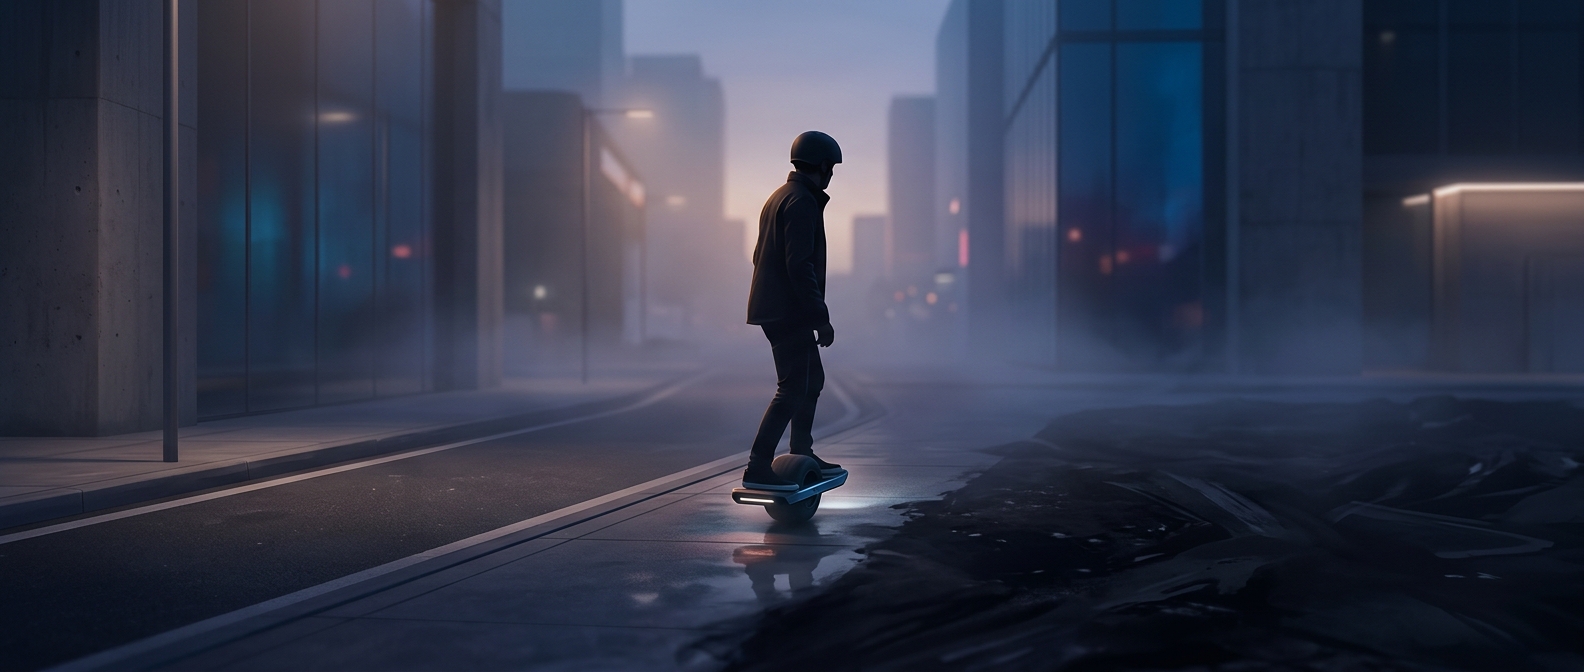
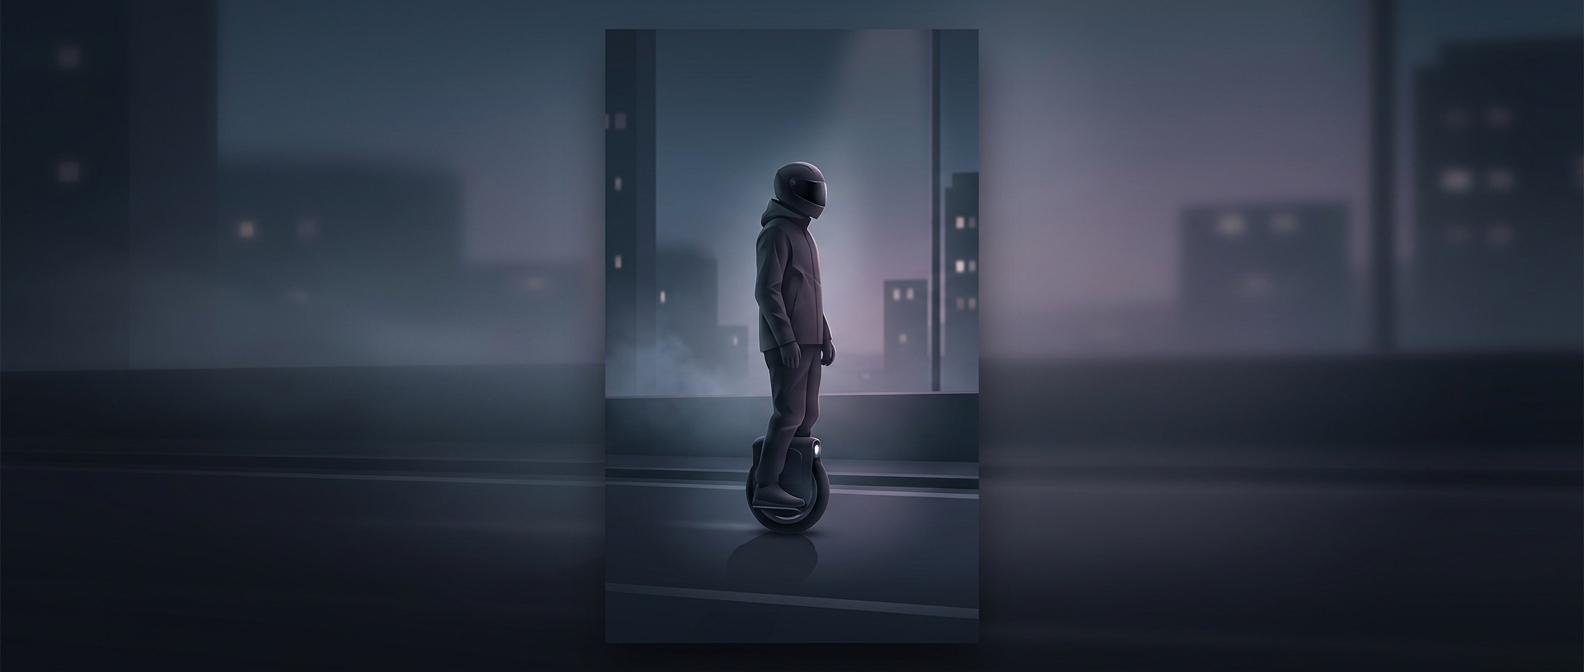
An electric unicycle is a compact version of a self-balancing robot. The rider stands above a single wheel, so the arrangement is naturally unstable: if the body tips forward, the wheel must move forward beneath it or the rider will fall. A motor makes that quick movement possible.
Inside the wheel, motion sensors track changes in tilt and acceleration. A controller uses those readings to adjust the motor’s torque—the force that turns the wheel. Leaning forward shifts the rider’s weight and prompts the wheel to drive ahead; leaning back calls for it to slow or roll backward. The rider is not simply being carried: their posture supplies the command, while the motor supplies the rapid response.
What the Wheel Can—and Cannot—Correct
The balancing system mainly handles tipping forward and backward. It does not make every part of riding automatic. Riders still use their bodies to steer, manage side-to-side balance, and respond to bumps, slopes, and slippery ground. A sudden obstacle or a demand beyond the motor’s ability to accelerate or brake can outrun the correction.
That division of labor is why the ride can look strangely effortless. The rider makes small, continuous shifts; the wheel turns those shifts into motion and catches the larger fore-and-aft wobbles before they become falls. The apparent stillness is not the absence of balancing—it is the result of balancing happening too quickly and subtly to see.