A vehicle designed around the Moon’s limits
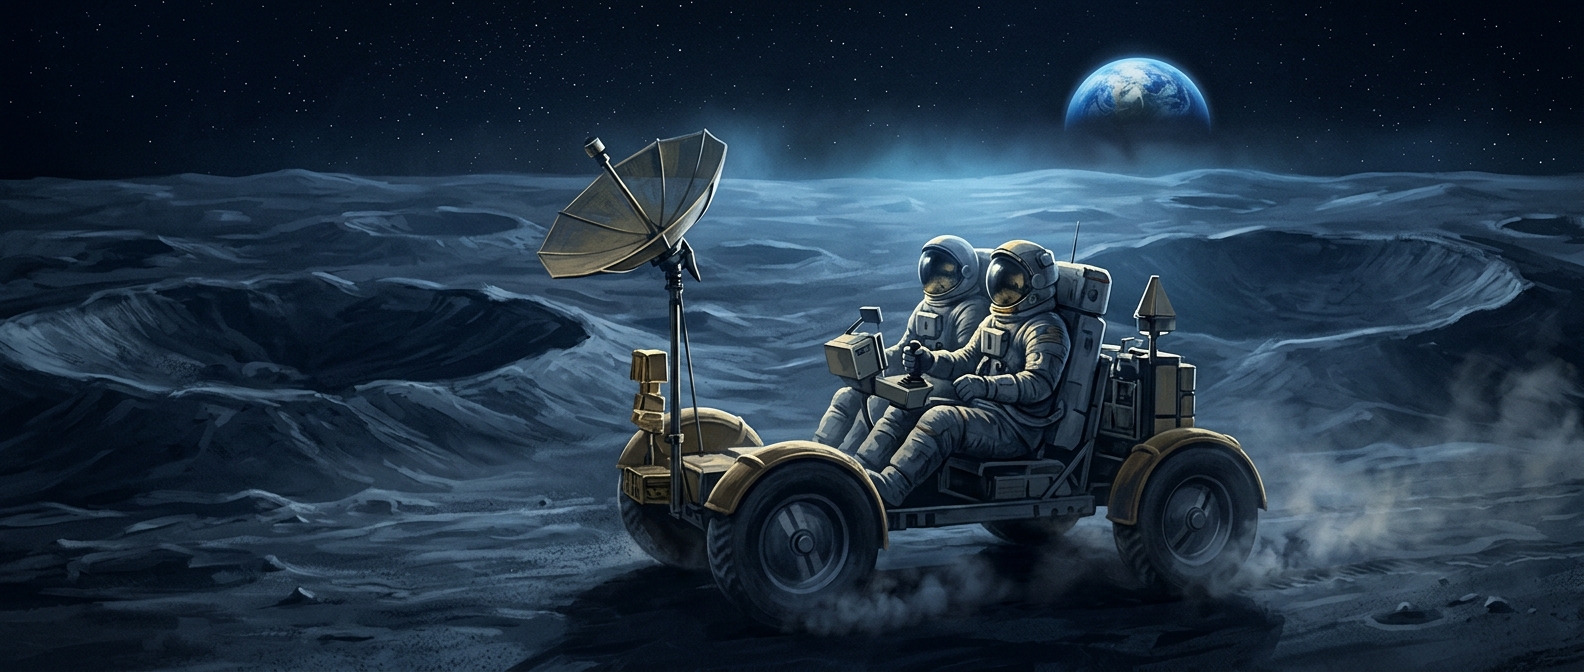
A lunar rover had to survive a trip folded against the outside of a lander, then unfold into a working vehicle in the Moon’s harsh terrain. Ordinary car tires were a poor fit: rubber could become brittle in extreme temperatures, and a conventional inflated tire would be difficult to repair far from Earth. The rover instead used springy wire-mesh wheels with metal treads. They could flex over uneven ground while giving the wheel a firm shape without trapping loose lunar dust.
Four small drives, one hand controller
Rather than sending power through a single engine and a complicated set of axles, the rover used an electric motor at each wheel. That arrangement let the wheels turn independently and helped the vehicle keep moving when its tires met different patches of rough ground. Steering was also built into the wheel system: the front and rear wheels could turn, allowing the rover to make tighter turns than a long vehicle with front-wheel steering alone.
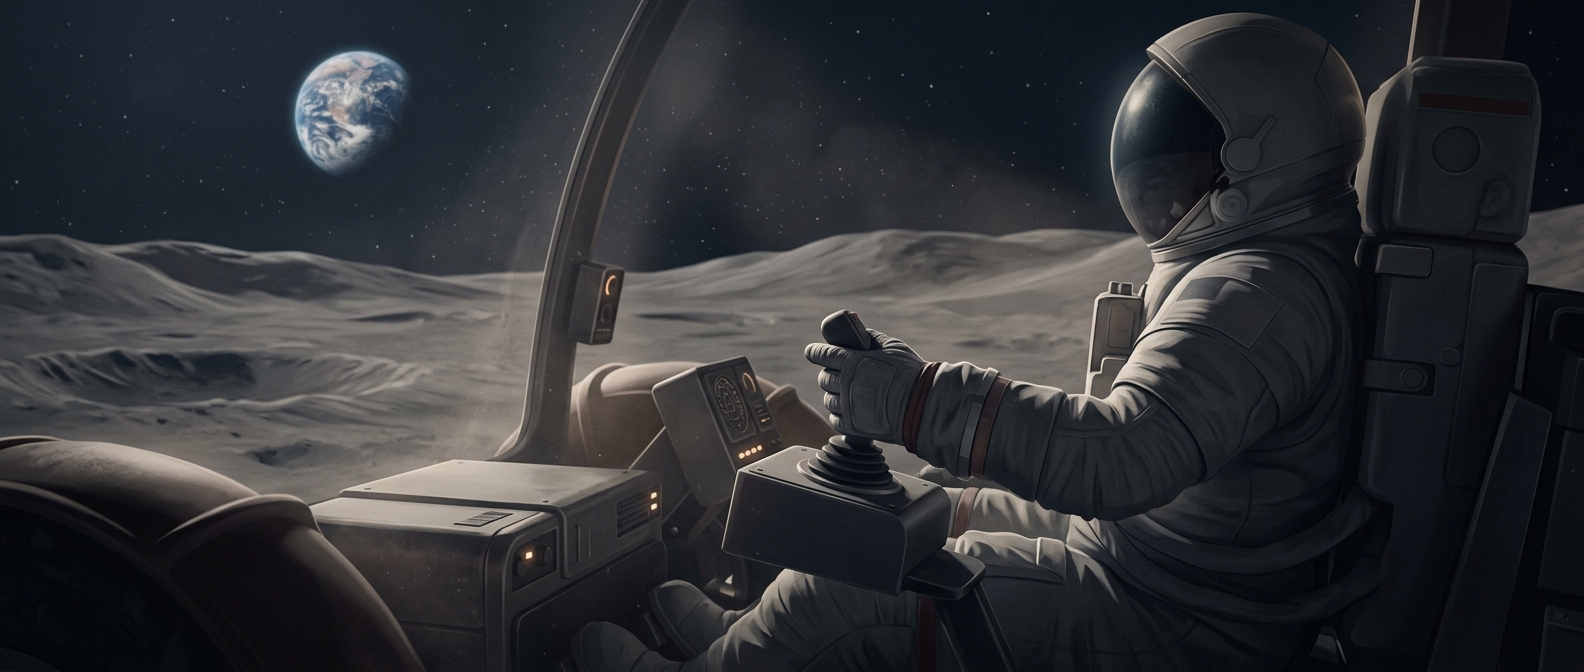
The astronaut at the controls used a hand controller to command movement and steering. That made driving more like managing a compact electric vehicle than operating a car with familiar pedals and a steering wheel. The lunar surface still demanded care: loose soil, rocks, and slopes could affect how the rover handled, and a wrong turn could consume precious time and battery power.
Why the rover changed the work
The rover let Apollo crews travel farther from their lander than they could comfortably walk in bulky spacesuits. That expanded the ground they could inspect and the rocks they could bring back, turning a limited landing area into a much wider field of exploration. Its design made the tradeoff clear: the vehicle was light and simple enough to fly to the Moon, but capable enough to carry astronauts across terrain no road crew had ever prepared.