A shape emerges from nearby decisions
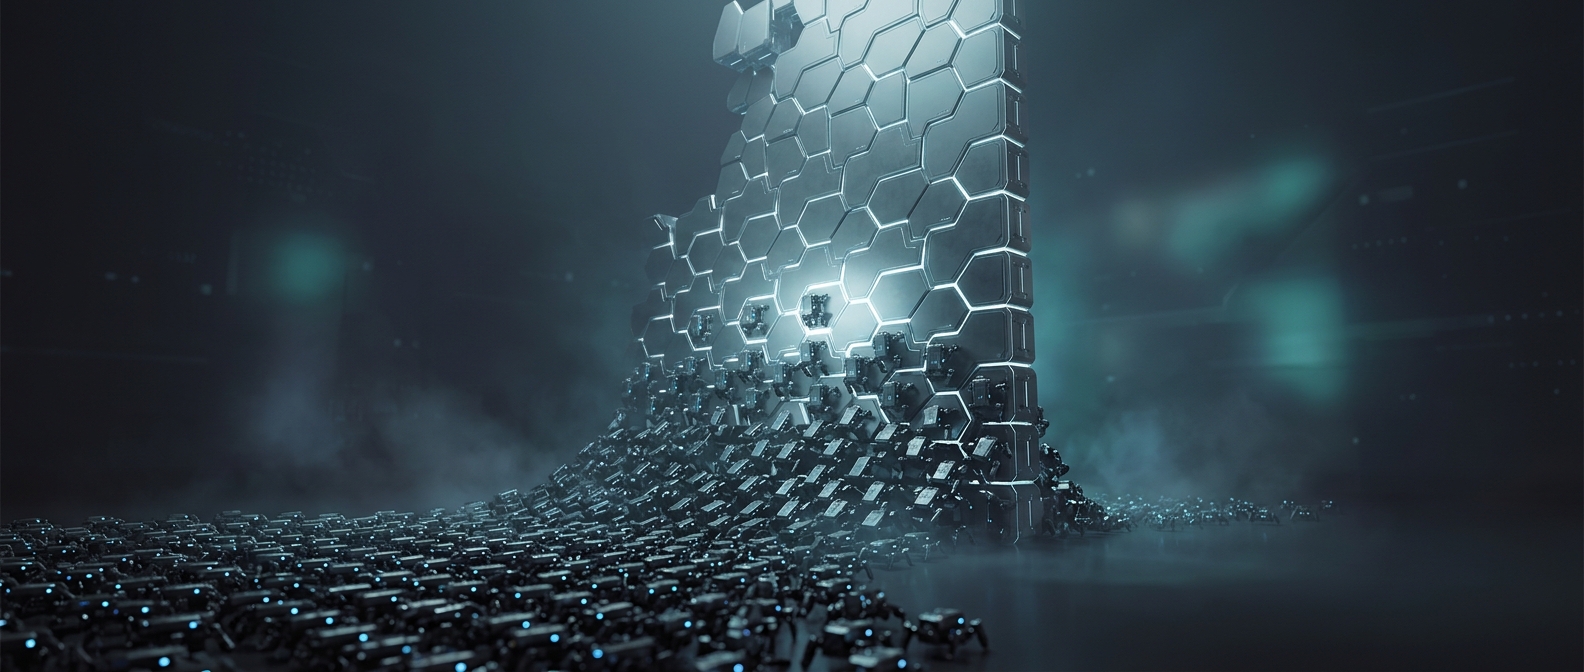
A swarm can make a coordinated structure without any robot knowing the final plan. Each unit acts on information available close by: it detects neighboring robots, exchanges signals, and applies a small set of rules. Those local decisions accumulate across the group, allowing the swarm to form a boundary or extend a line of robots across an opening.
The key is that coordination is distributed. There is no central machine assigning every robot a precise location, and no single unit needs a complete map of the group. If one robot changes position or a gap appears, nearby robots can respond to the changed pattern of signals; their neighbors then respond in turn.
Infrared makes a simple channel for coordination
Infrared light—radiation just beyond the red end of visible light—lets nearby units exchange signals over short distances. That range is useful: a robot can base its decision on its immediate surroundings rather than trying to communicate with the entire swarm at once.
The robots’ rules turn those local signals into a kind of collective vote. A unit’s neighbors provide clues about whether it is at an edge, part of a line, or next to an opening. Repeated across many units, these small choices produce a group-level shape. The apparent intelligence belongs to the interaction among the robots, not to a hidden master controller.
Coordination comes with a tradeoff
This approach can make a swarm adaptable: a local disturbance need not require a central system to recalculate every robot’s assignment. But simple rules do not guarantee that every unit will move perfectly or that the group can create any shape on command. The result depends on what each robot can sense, how its rules are designed, and how reliably the units communicate.
That constraint is also the point. A structure can be built from many limited machines whose individual decisions are modest—so long as each one can read the pattern forming around it and respond.