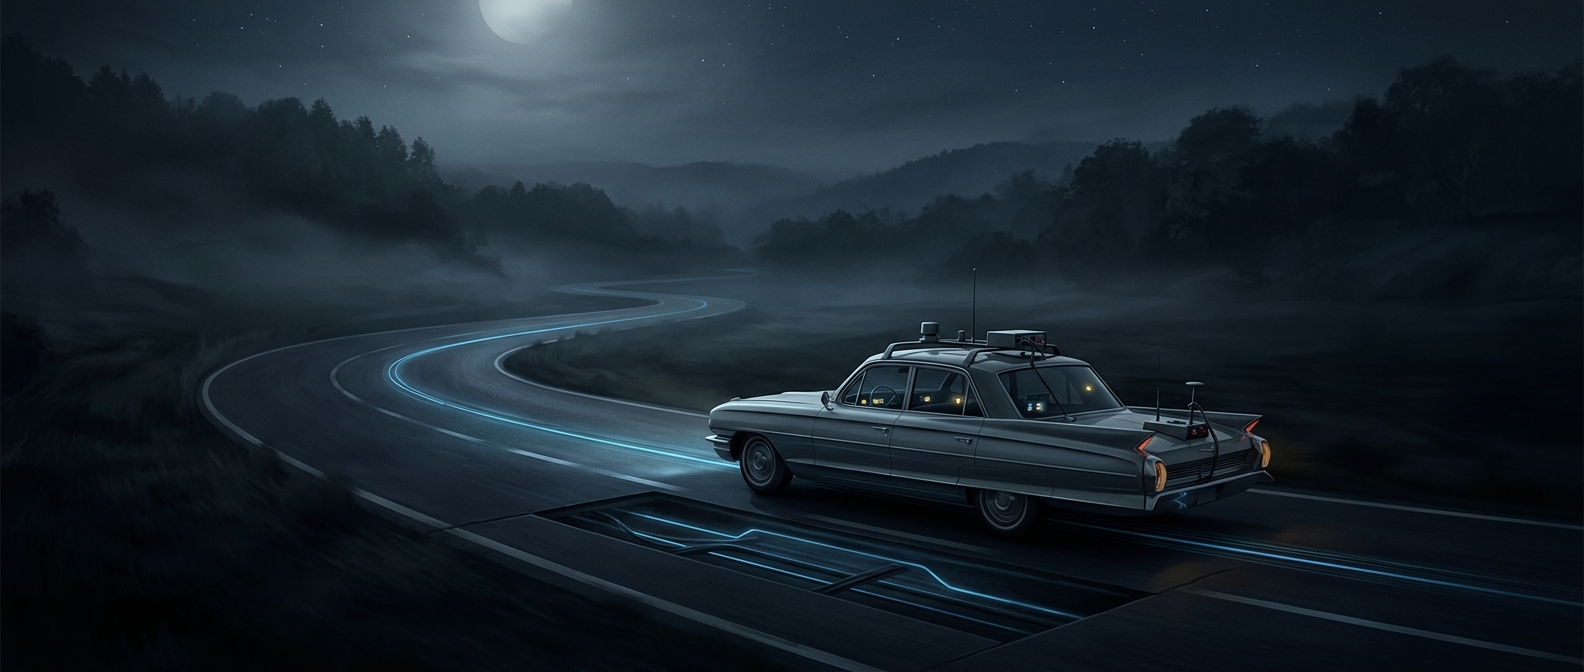
A magnetic track hidden in the pavement
The buried wire acted like an invisible guide rail. When an electrical signal ran through it, the wire produced a magnetic field. Sensors mounted beneath the car detected that field and helped its steering system keep the vehicle centered over the route.
That distinction matters: the car was not deciding where to go by reading signs or choosing among streets. The route had already been built into the road. The vehicle’s job was to follow the signal and make steering corrections as the wire curved.
The road supplied the guidance
This approach shifted part of the driving task from the vehicle to the infrastructure. Instead of relying on a person to steer every turn, the system used the wire’s changing path to tell the car where to go. The car still needed equipment to sense the signal and control its steering, but it did not need to understand a complex street scene in the way a modern autonomous vehicle must.
The tradeoff was straightforward: a guided car could follow a prepared course, but only where that course existed. Every route required a specially equipped roadway, and a car could not simply choose an unprepared road and continue under the same system.
That is why the buried wire was both the clever part and the limitation. It made automated steering possible by turning the pavement into a precise guide—but it also meant that, on this route, the road had to lead the way.